Tech
What sits behind the screenshots — the stack, how each thing is built, a robot coming together part by part, and the rooms where the hackathons happened.
stack
languages
TypeScript, C++, Python, JavaScript, SQL
frameworks
Next.js, React, tRPC, Motion
systems & tools
Supabase, Pusher, Vercel, Render, Git
focus
competitive programming, AI / ML systems, product design
Building education systems at the intersection of AI, product, and competition.
how it’s built
infrastructure
Studious
Next.js frontend on a tRPC backend; Pusher sockets for realtime, Supabase read replicas, load balancing on Render and Vercel at the edge.
→
ML · audio
notate
A decoder-only Transformer (6 × 512, 8 heads, ~21M parameters) trained on REMI-tokenised MIDI, played through a polyphonic synth written as a Web Audio AudioWorklet.
→
AI · hardware
Foundry
A project-aware copilot with streaming tool execution; mechanical CAD in KCL, schematic and PCB workspaces, a Monaco editor with Yjs multiplayer, Shopify checkout.
→
speech · vision
Synapse
Emotion read from voice tone and facial expression, attached to each message, and played back as expressive speech in the sender’s cloned voice.
→
AI · full-stack
Scribe
Frontend redesign, backend infrastructure, and the inference design behind its AI study workflows.
→
graphs
Nomad
Course planning on prerequisite dependency graphs, with a social layer for finding classmates and communities.
→
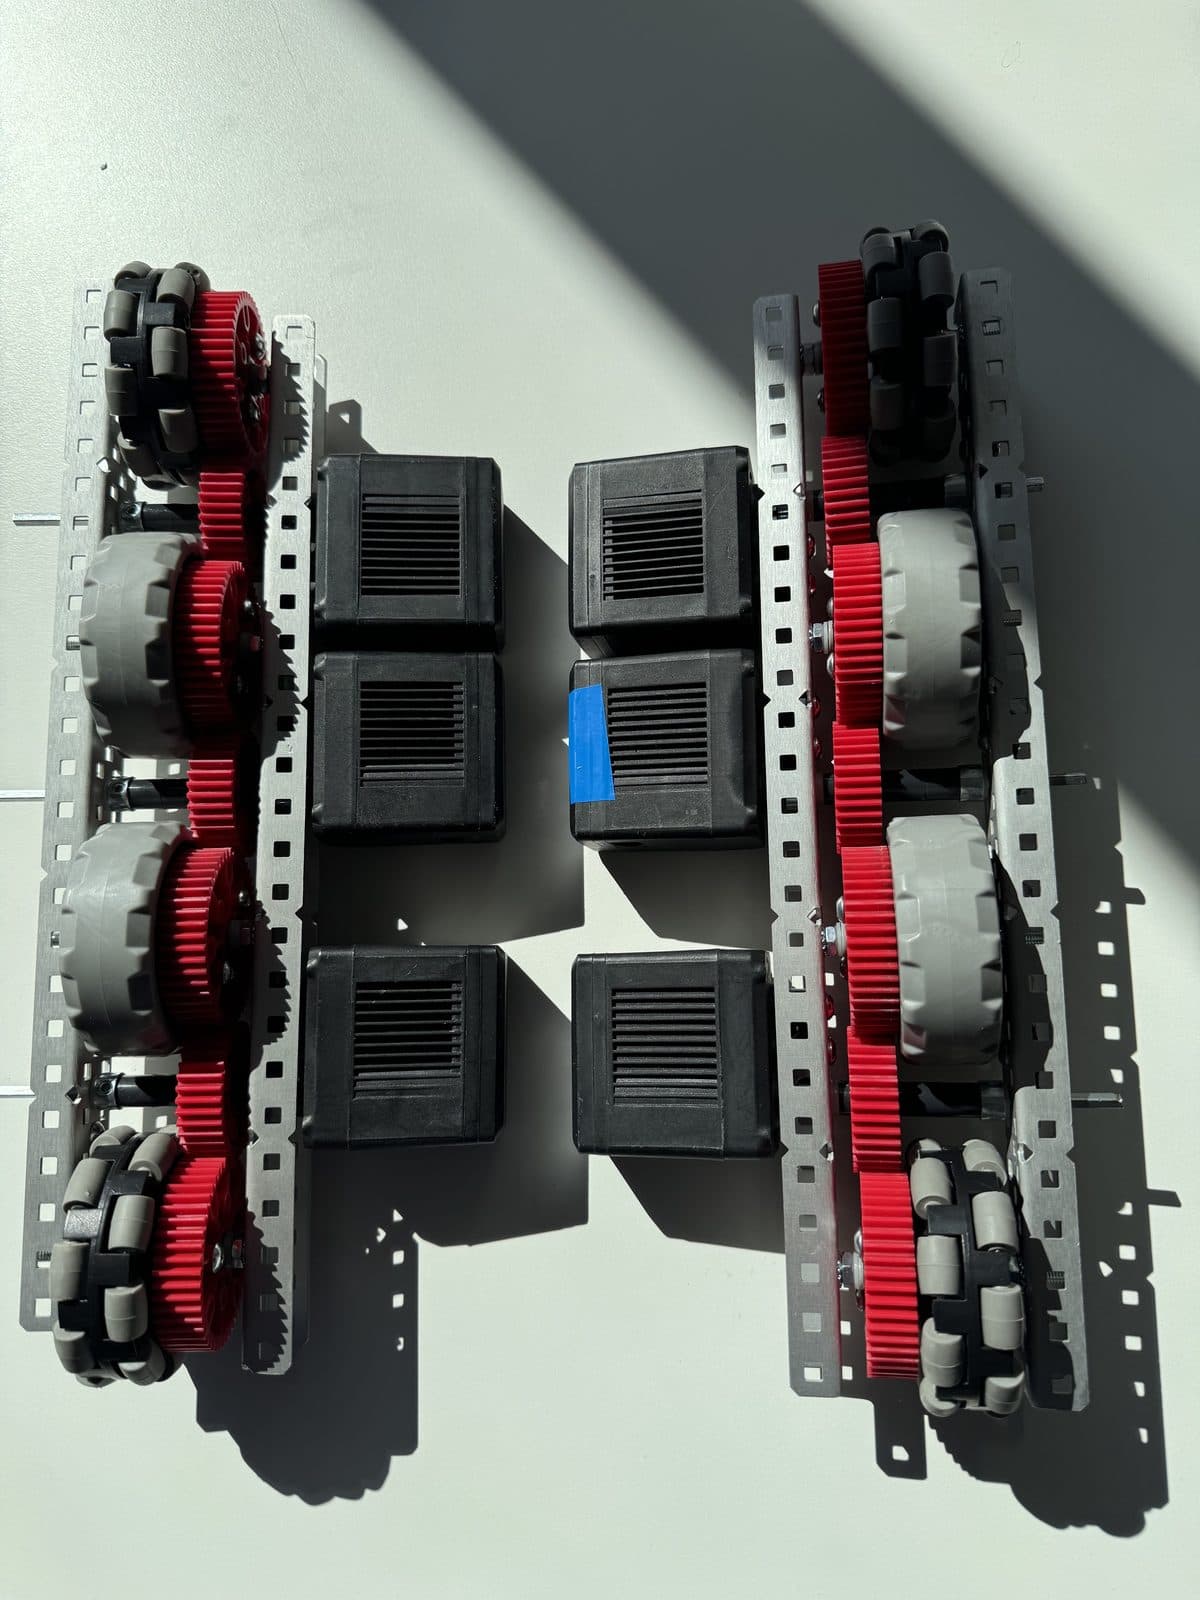
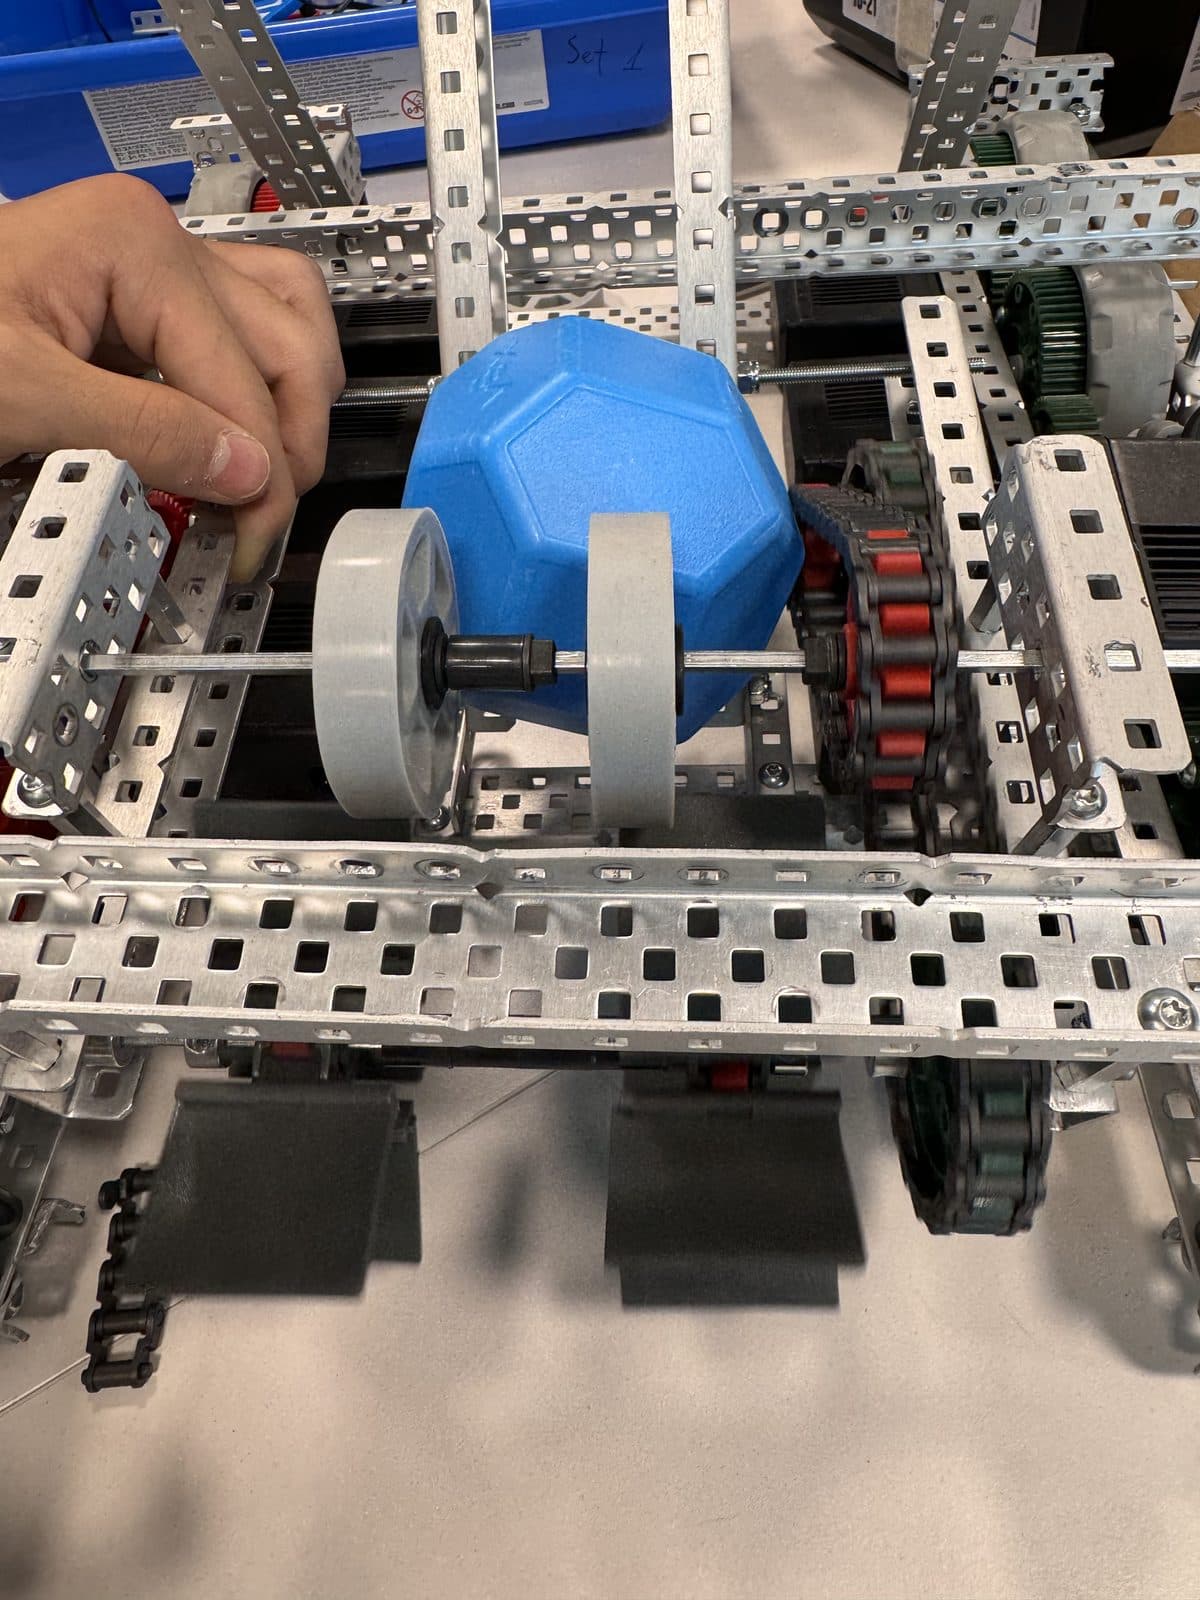
the robot
VEX team 15520X
engineer and programmer — 15520X (MECH_IT_HAPPEN)
- 3rd place skills and 3rd place qualifiers at Alpine Robo Games 2026.
- Ranked 4th Skills, 7th Overall at Swiss Regional Competition (Santa Clash @ ISBasel).
- Assisted in robot creation and design.
- Engineered autonomous control mode.
- Programmed interface for human interactions (controller).
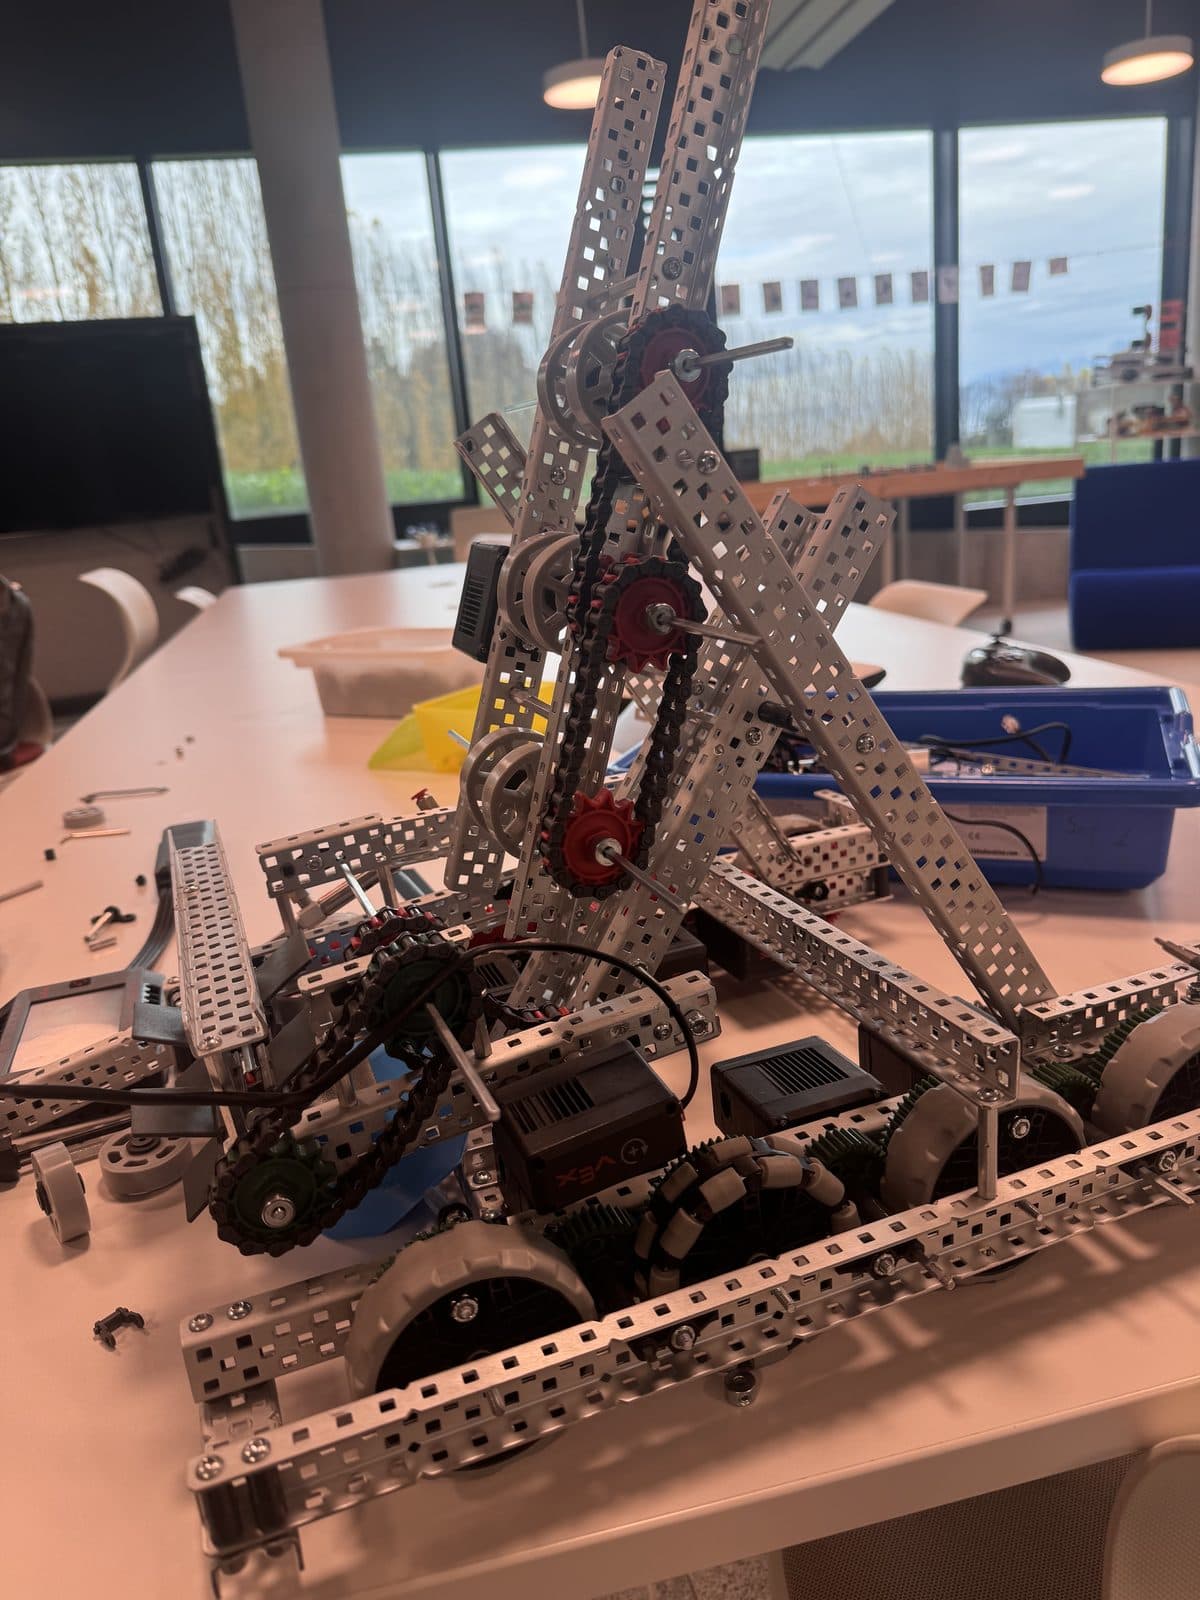
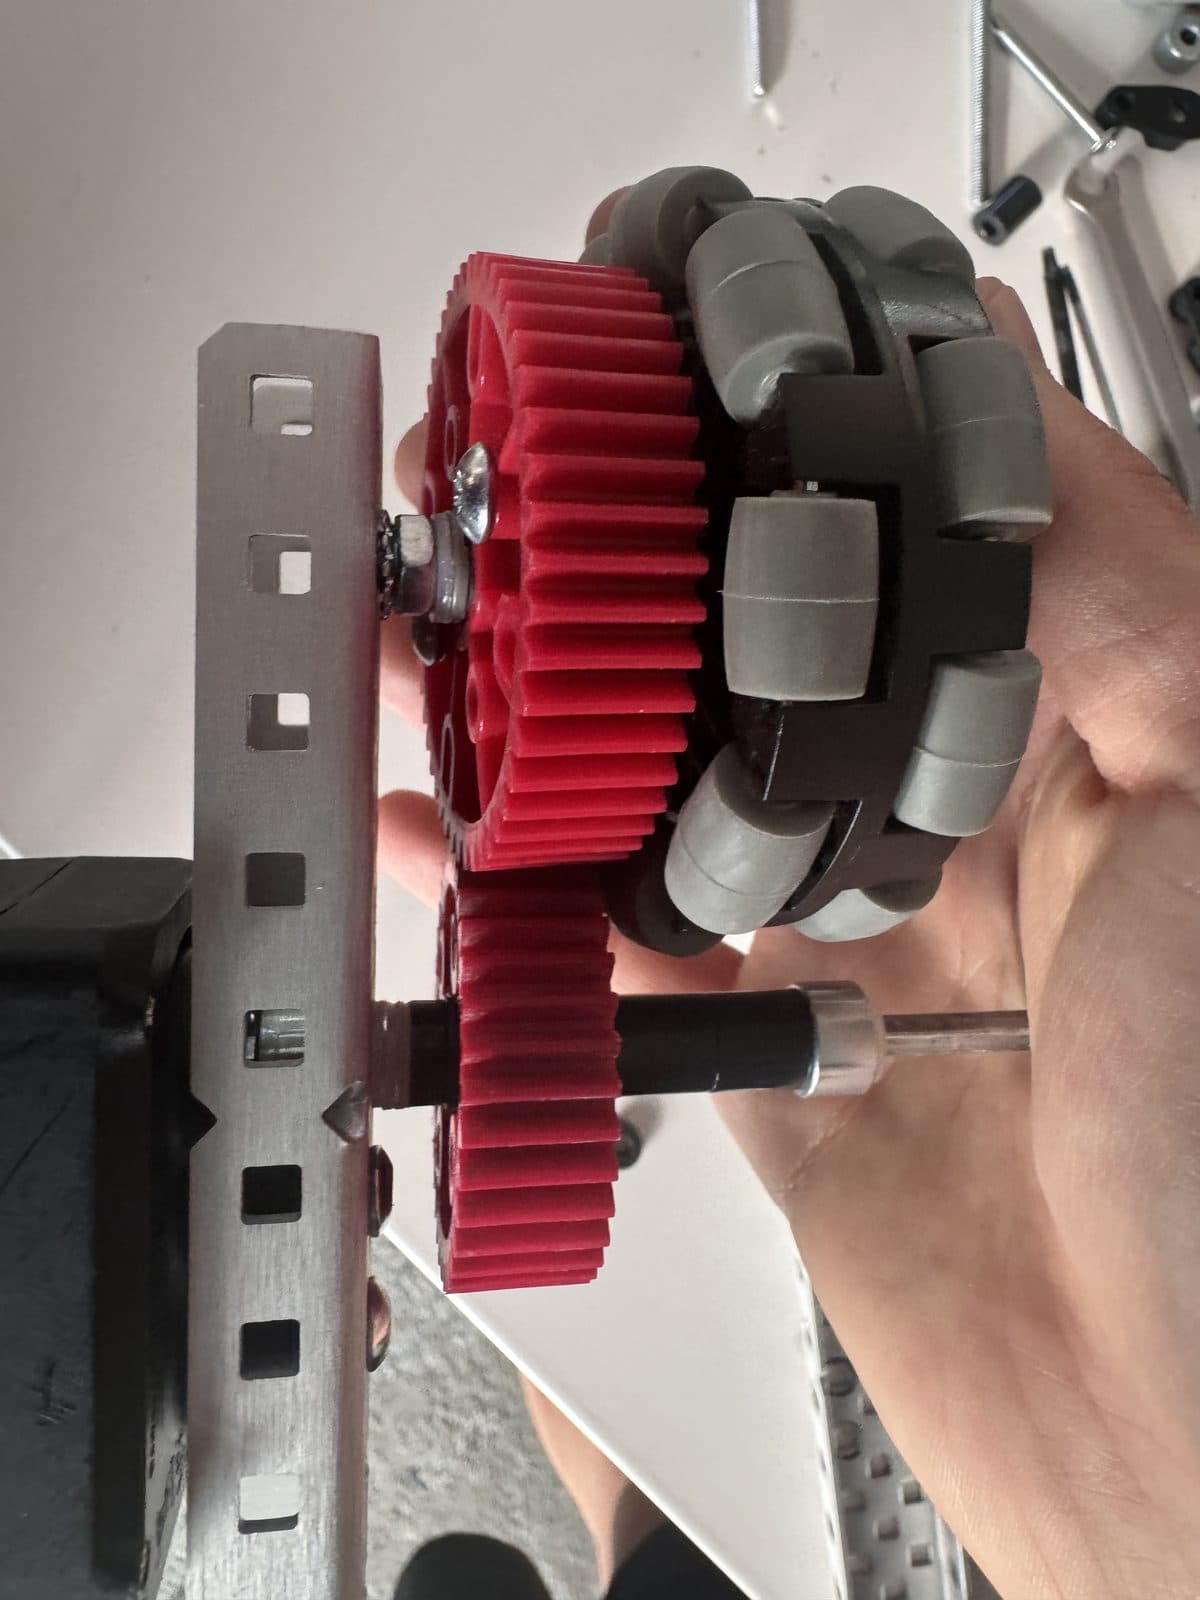
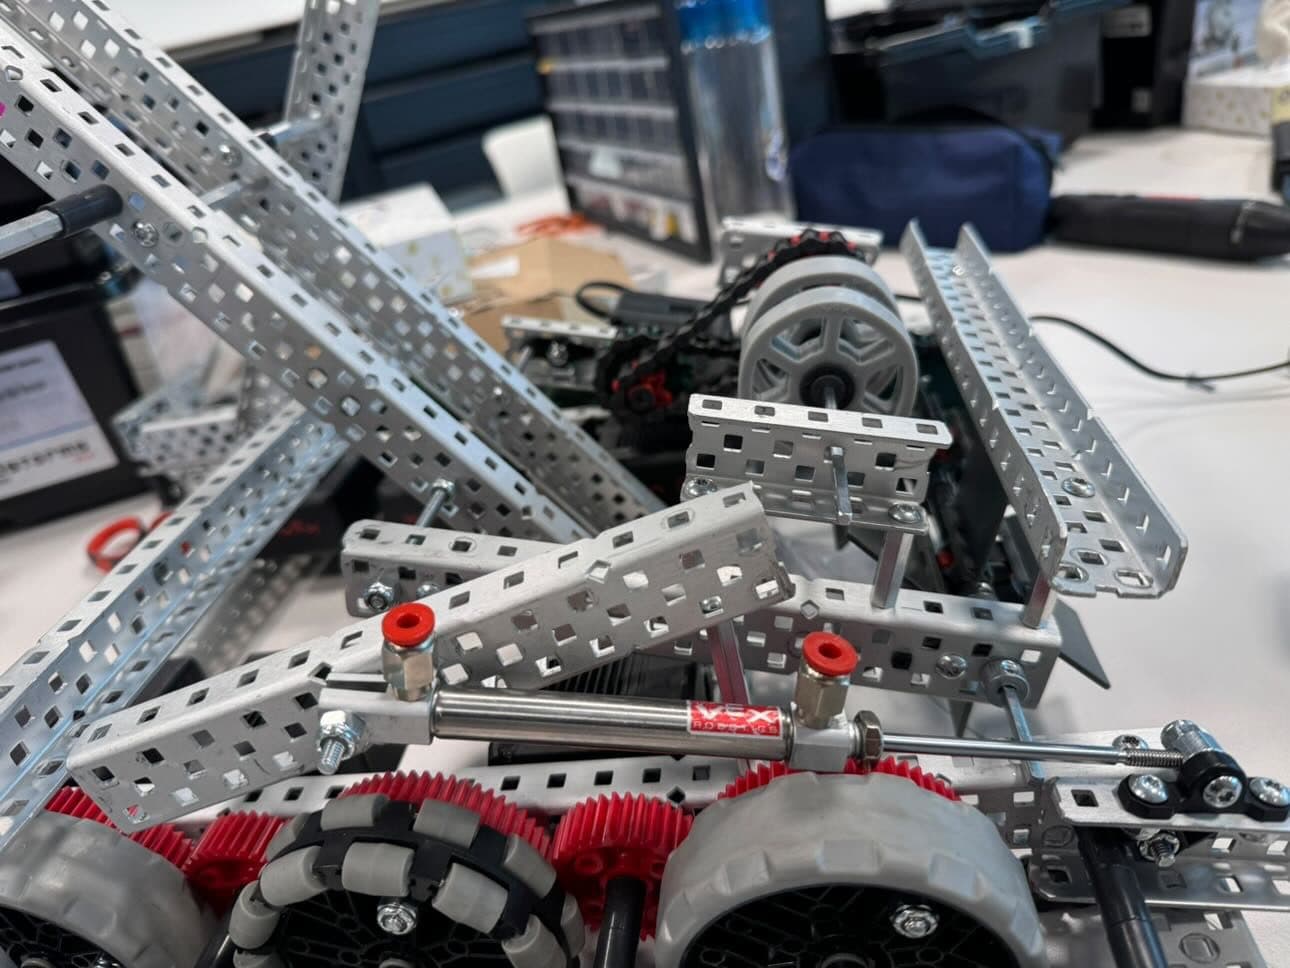
on the board
hackathons
Nov 2025
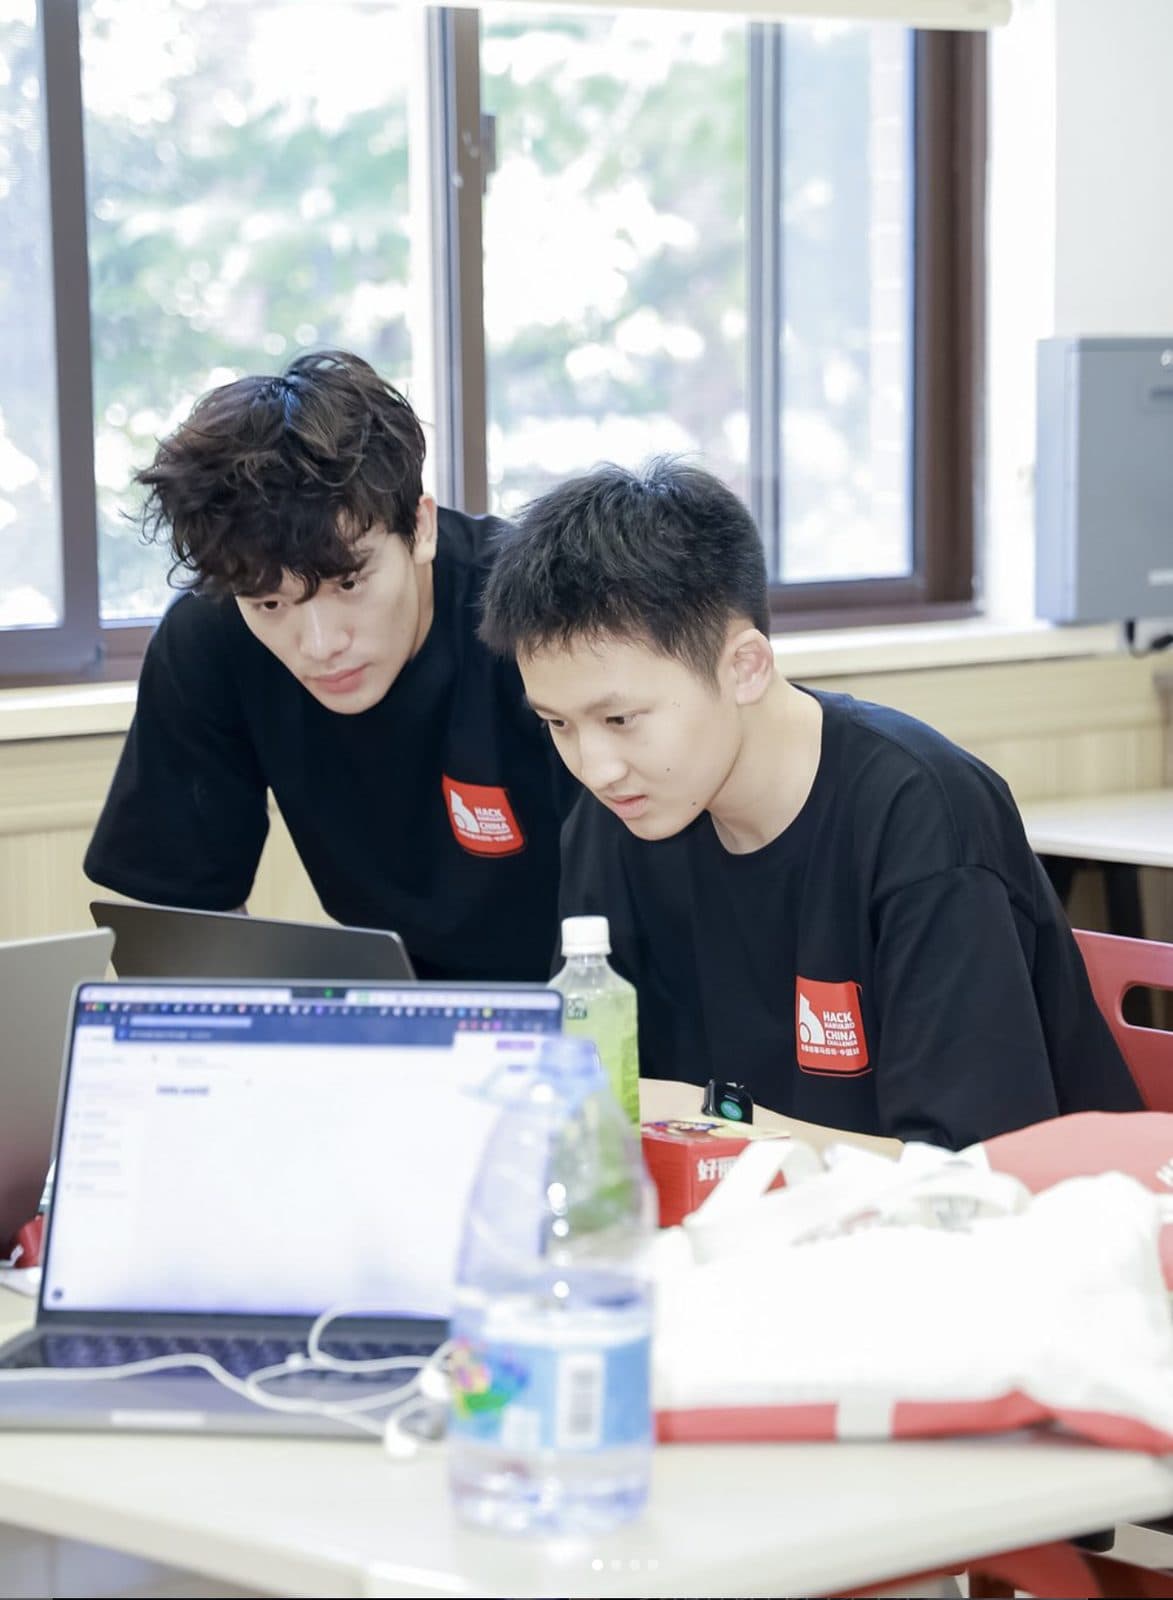
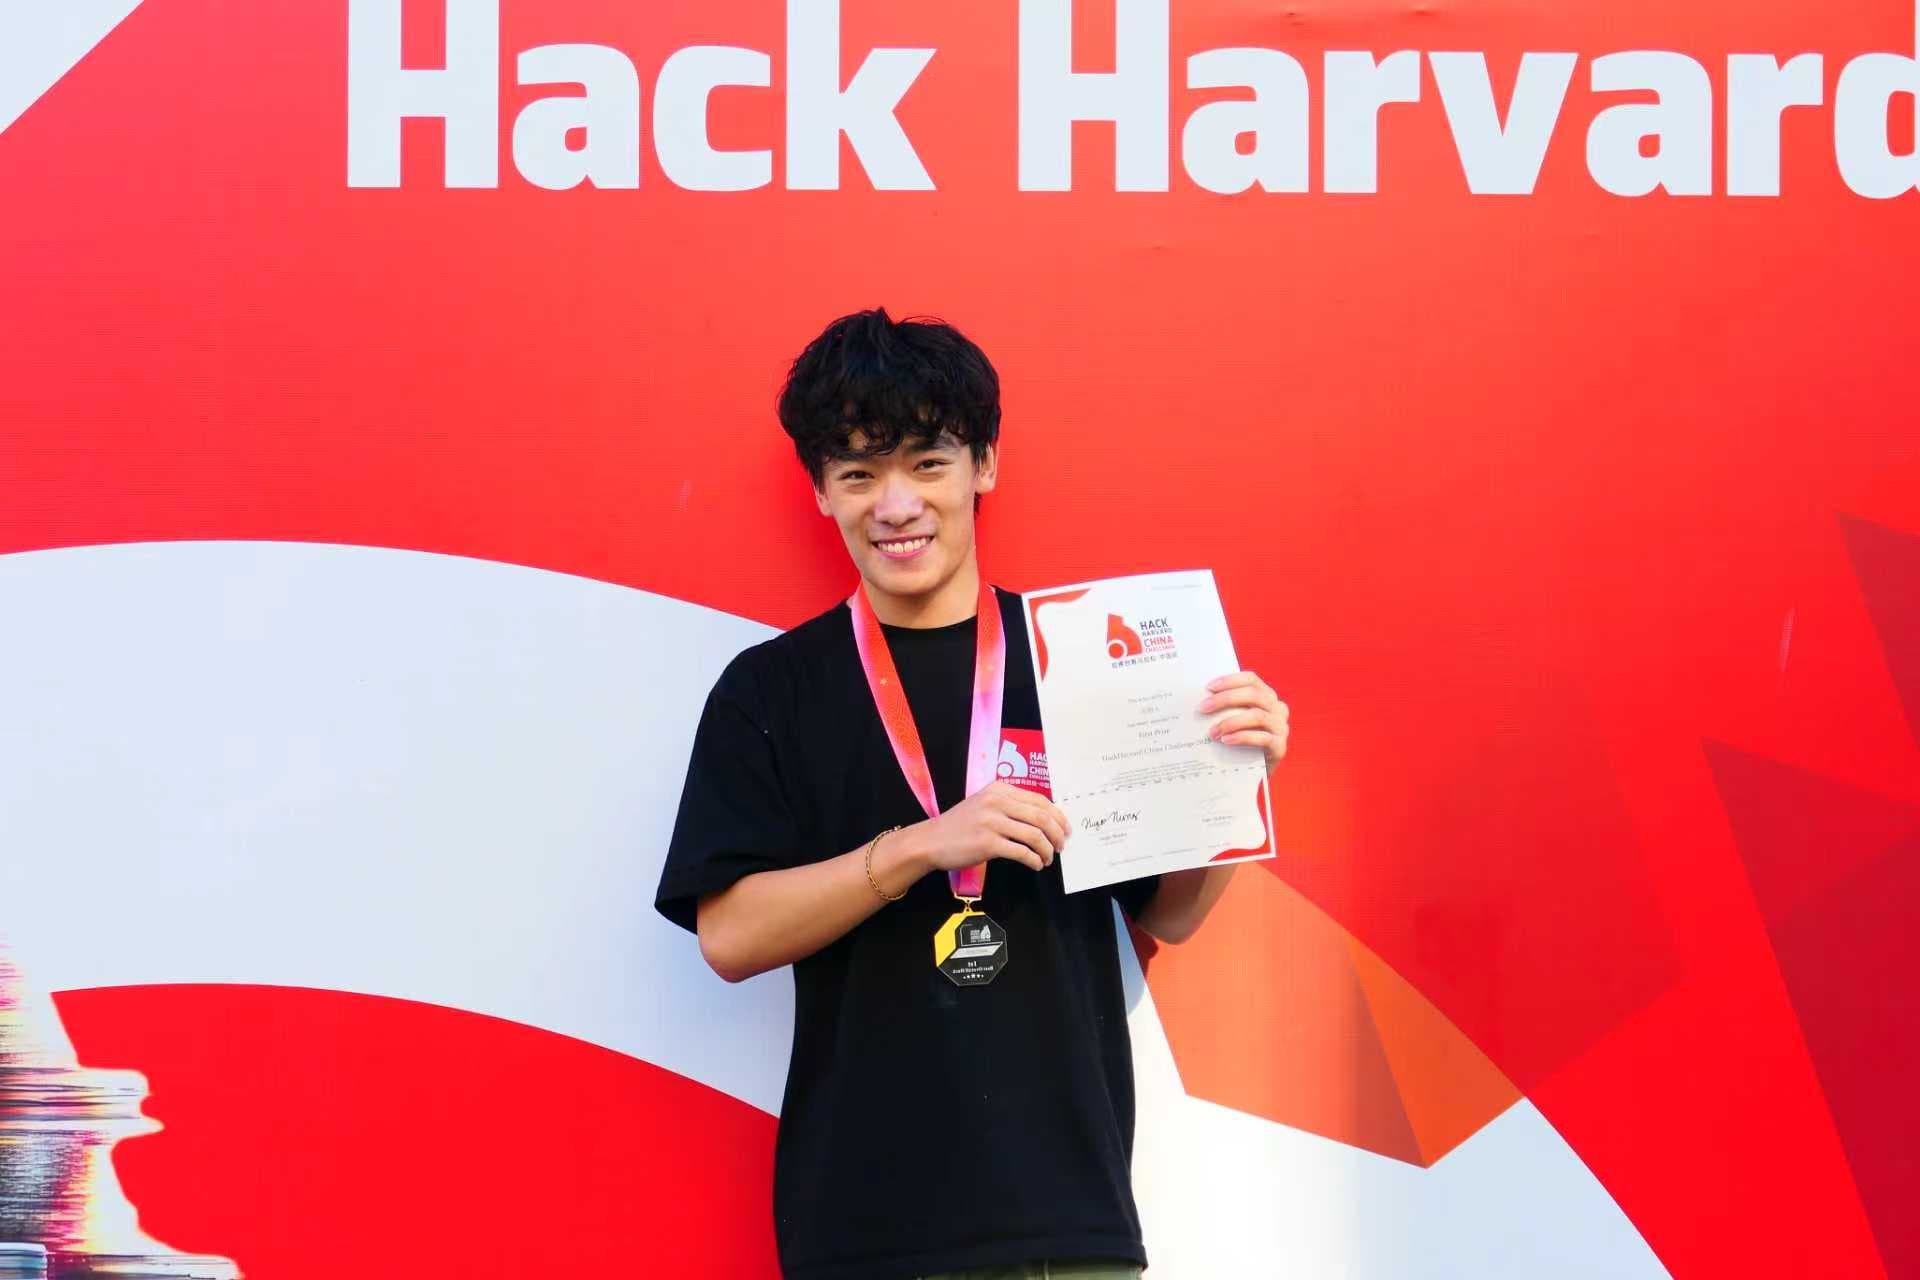
HackHarvard 2025 China — 1st Place
1st Place Overall, "Best Overall Hack" Winner.
Mar 2026
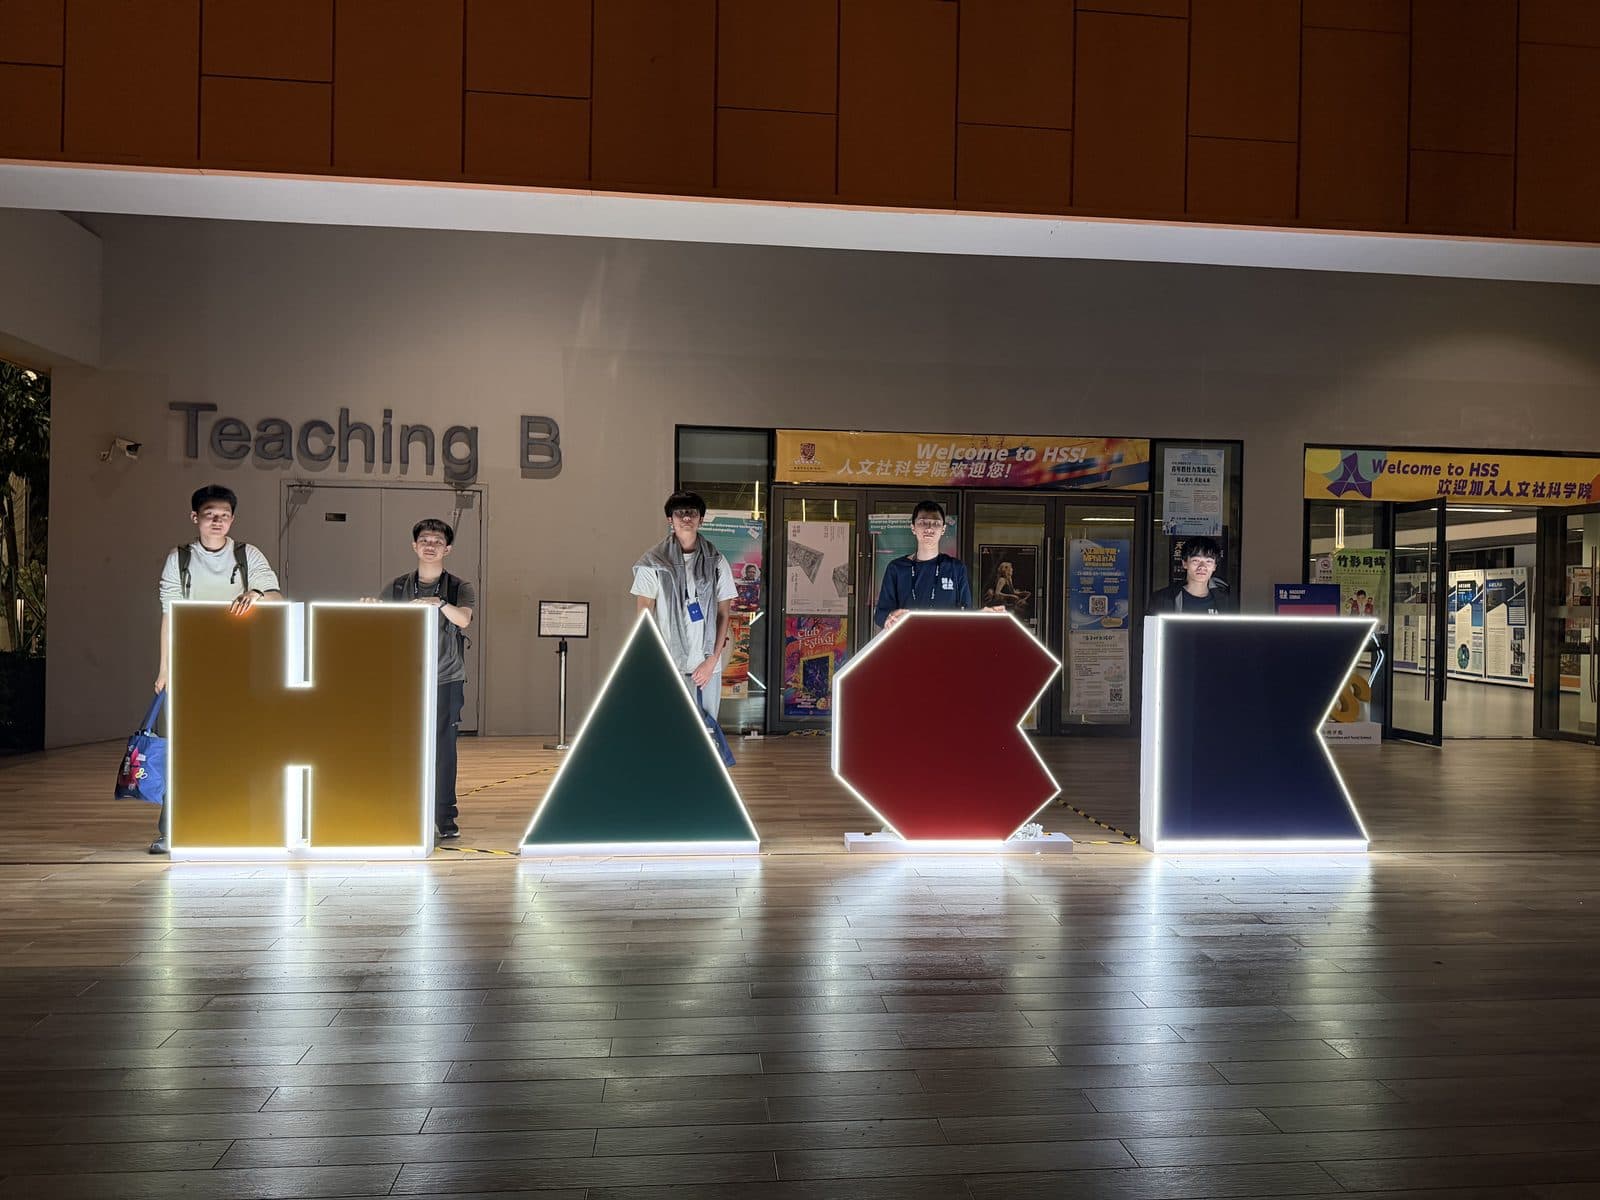
HackMIT China 2026 — 3rd Place (Education Track) & Outstanding Impact Award
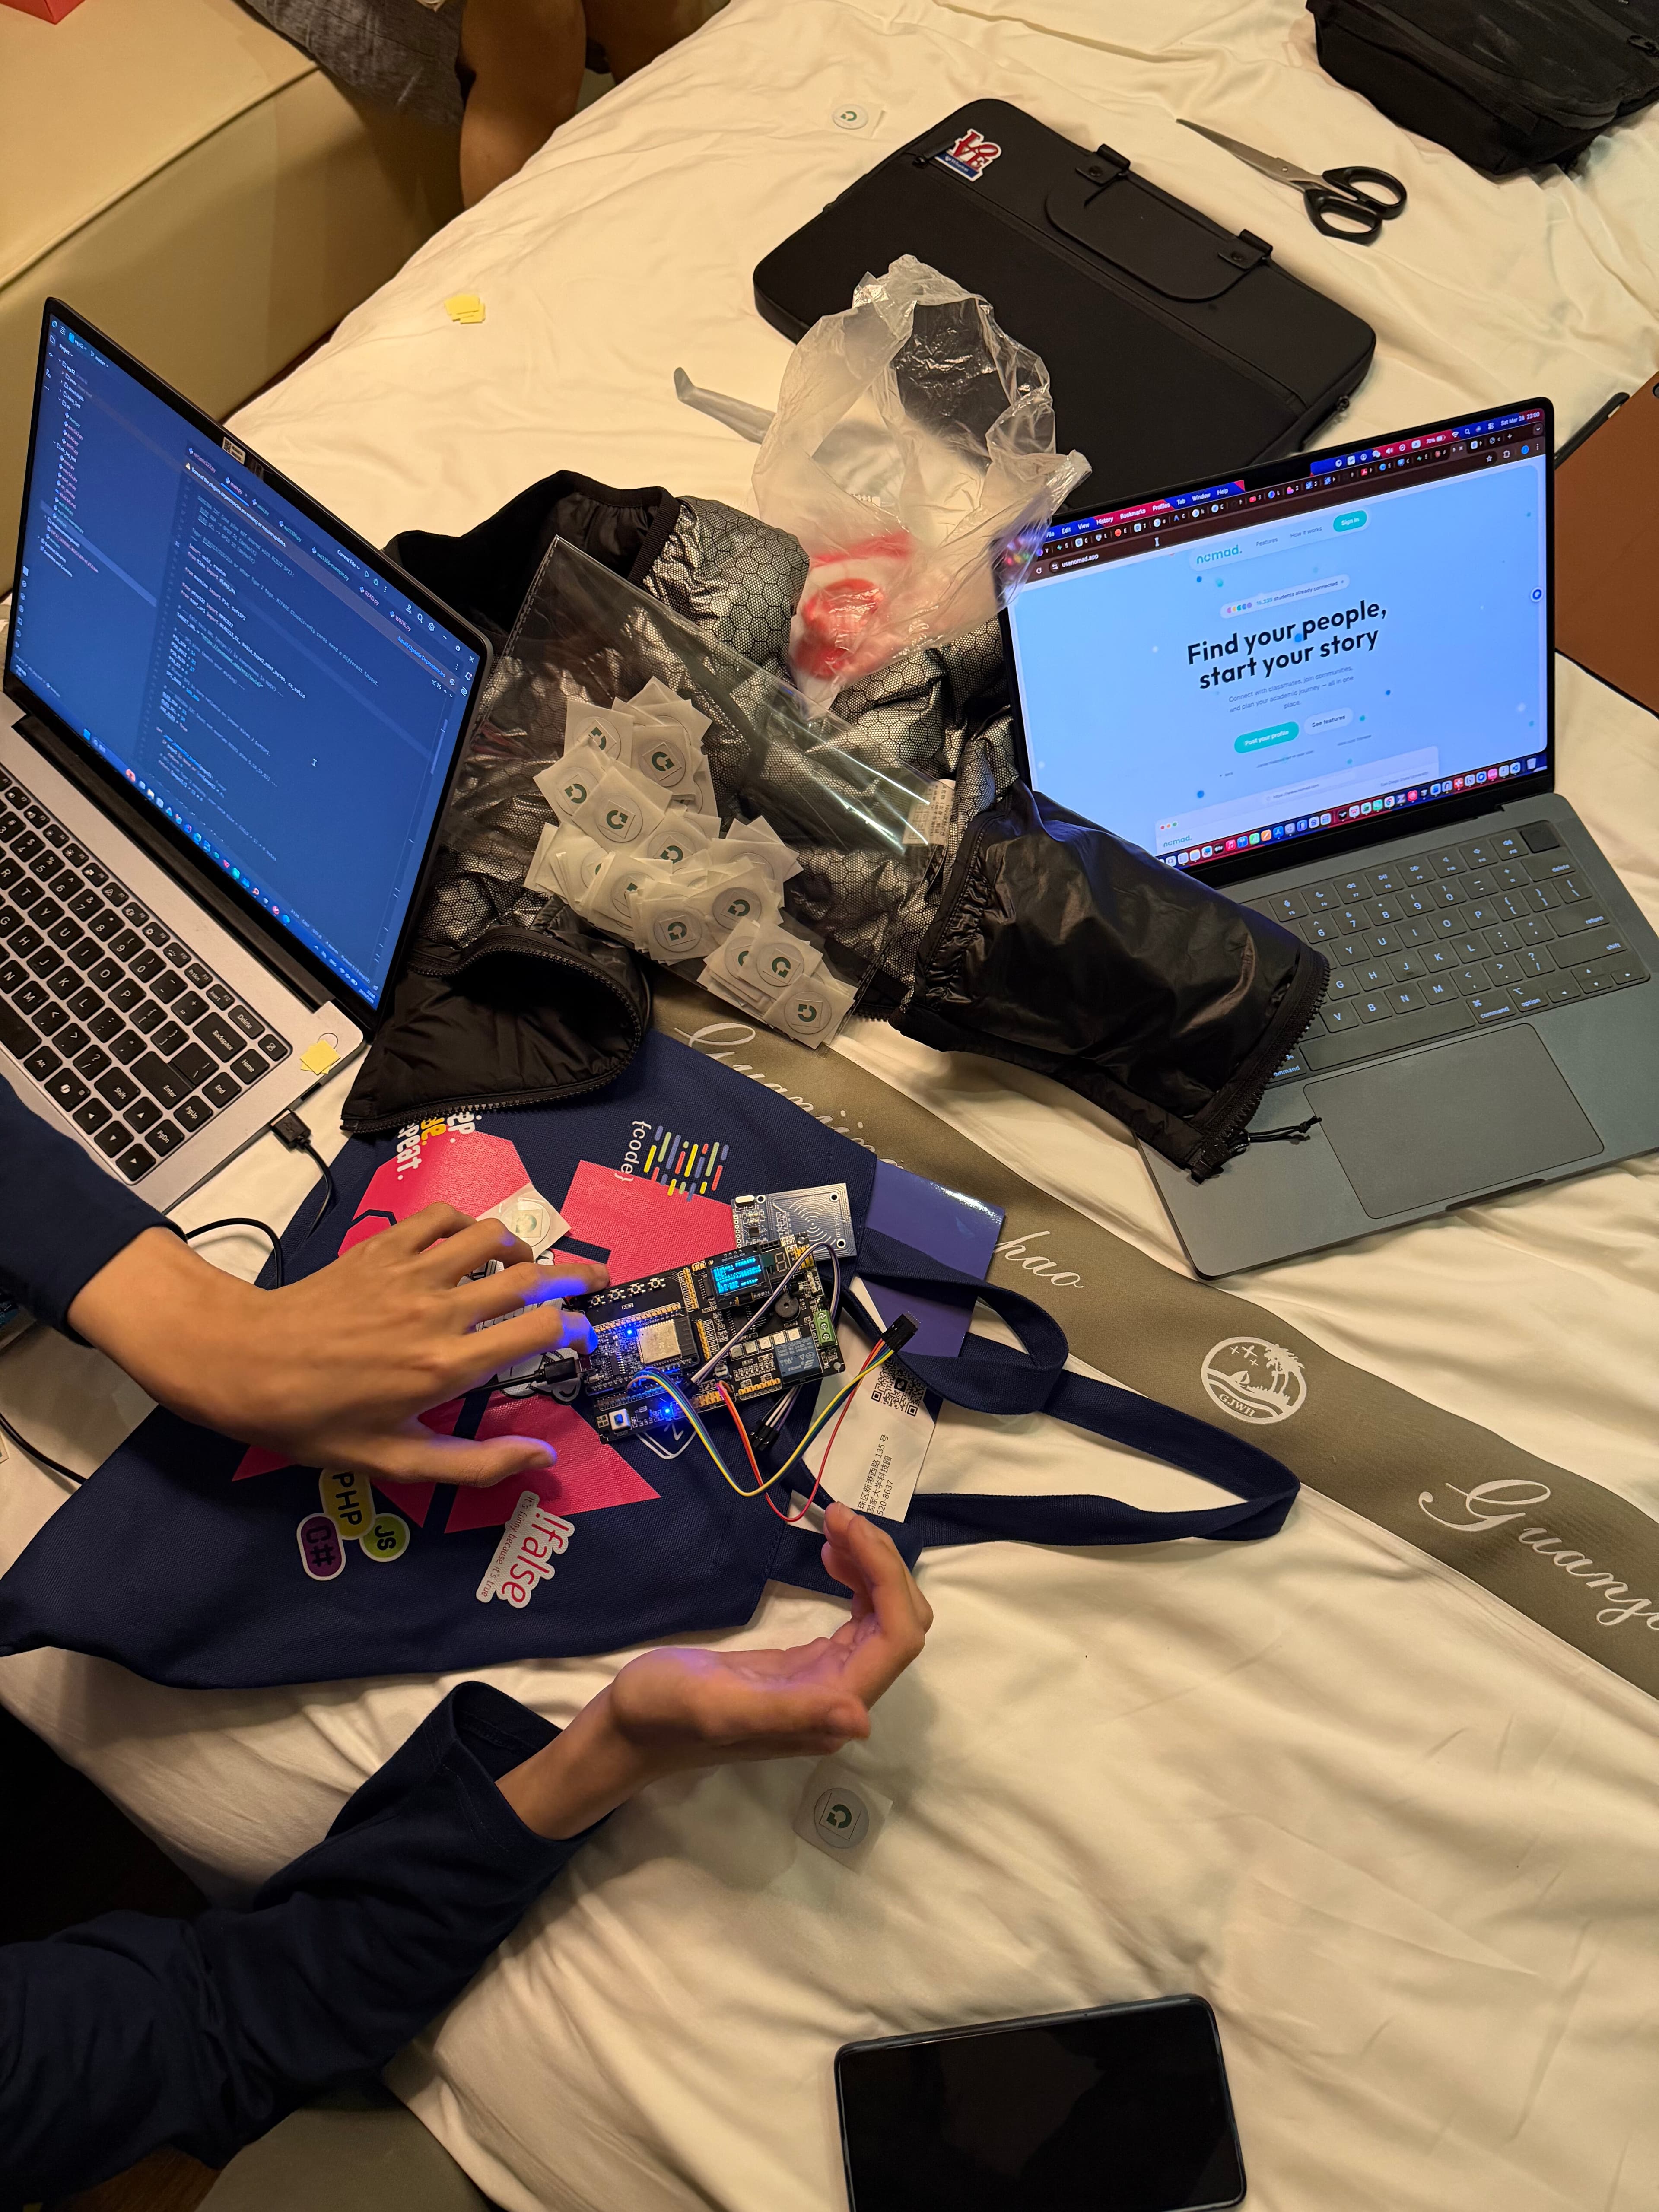
Podium finish out of 300+ participants during the 2026 HackMIT China Challenge. Built Nomad in 36 hours.
Oct 2025
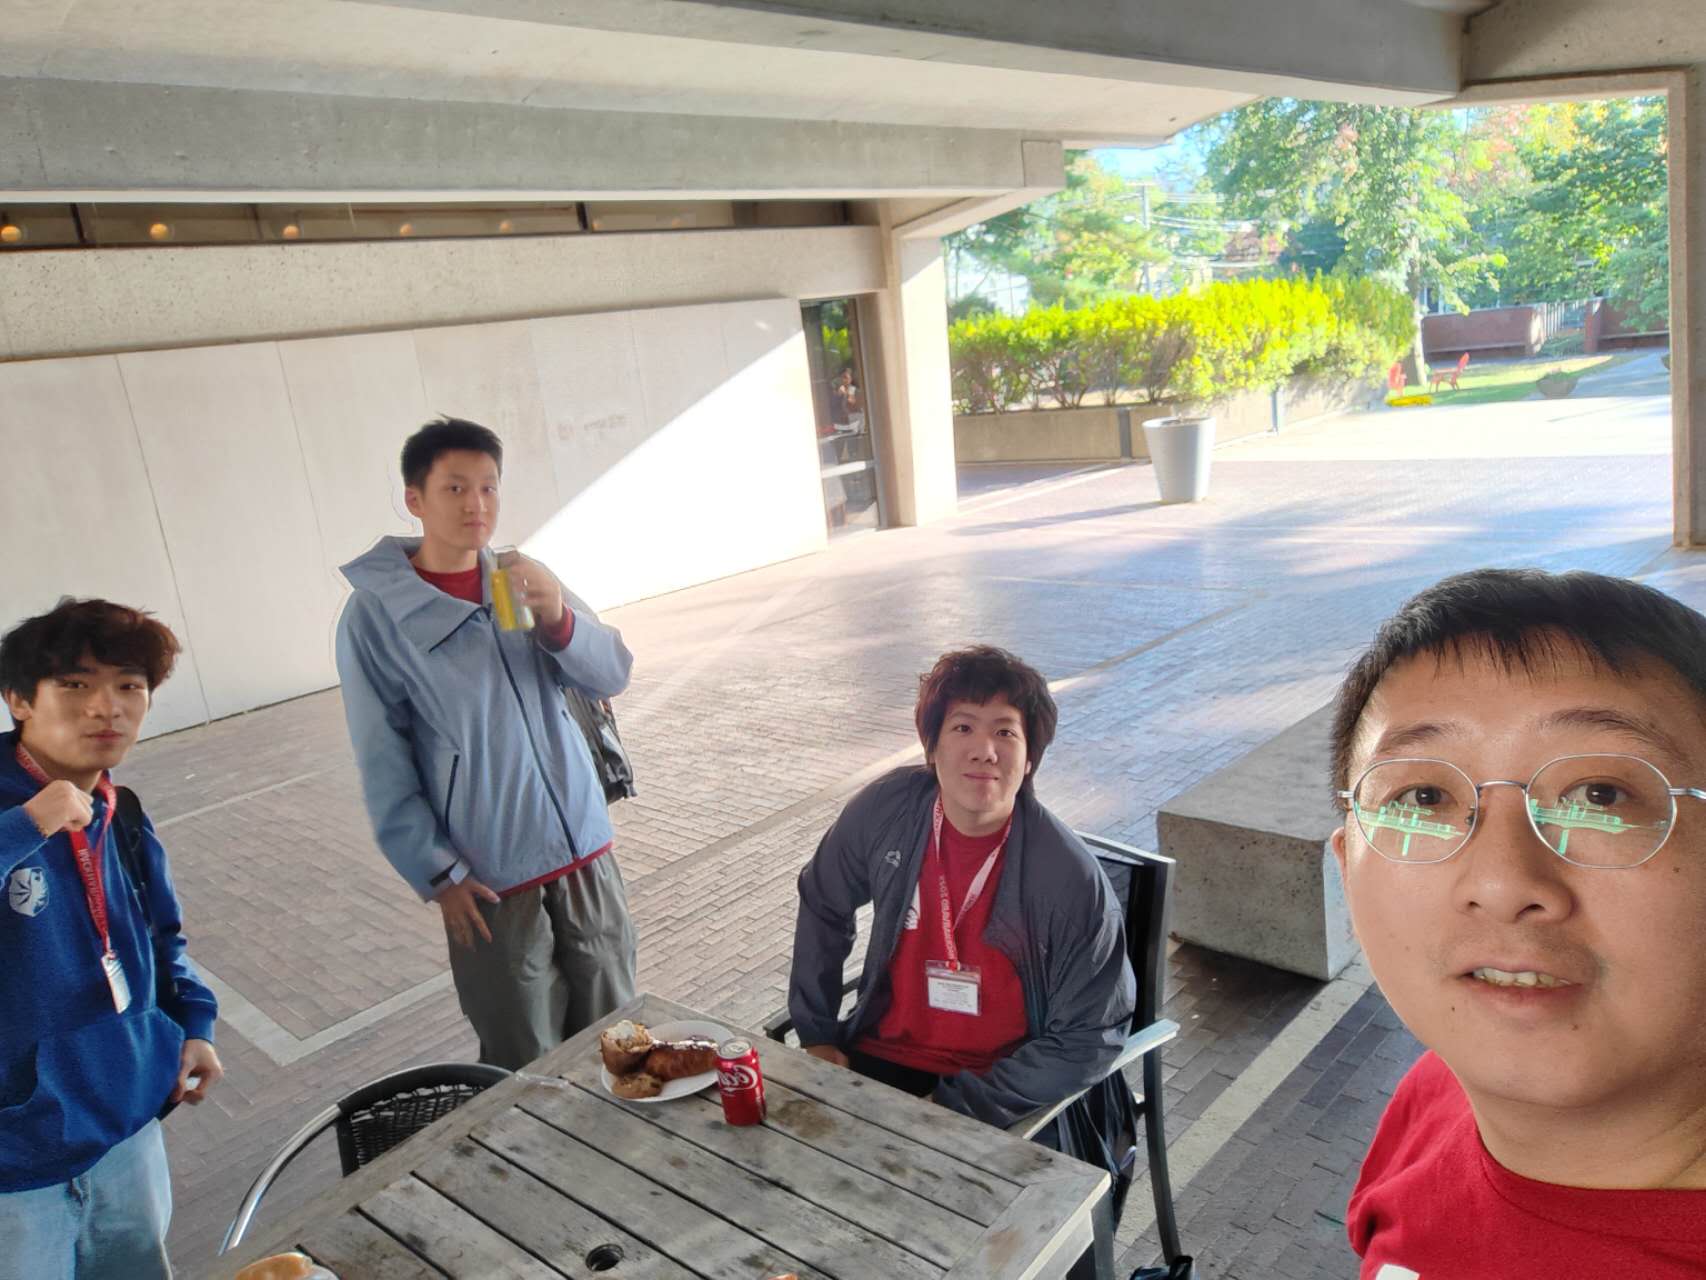
HackHarvard 2025 — Compile the Decade (Invitational)
Invited as one of only two high school teams to attend HackHarvard 2025.
2025
Empower 3.0 Hacks — 3rd Place
3rd Place, "Coding" track; 450+ participants in total.